> For the complete documentation index, see [llms.txt](https://yagsl.yassrobotics.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://yagsl.yassrobotics.com/how-to-guides/troubleshooting-flowchart.md).
# Troubleshooting flowchart
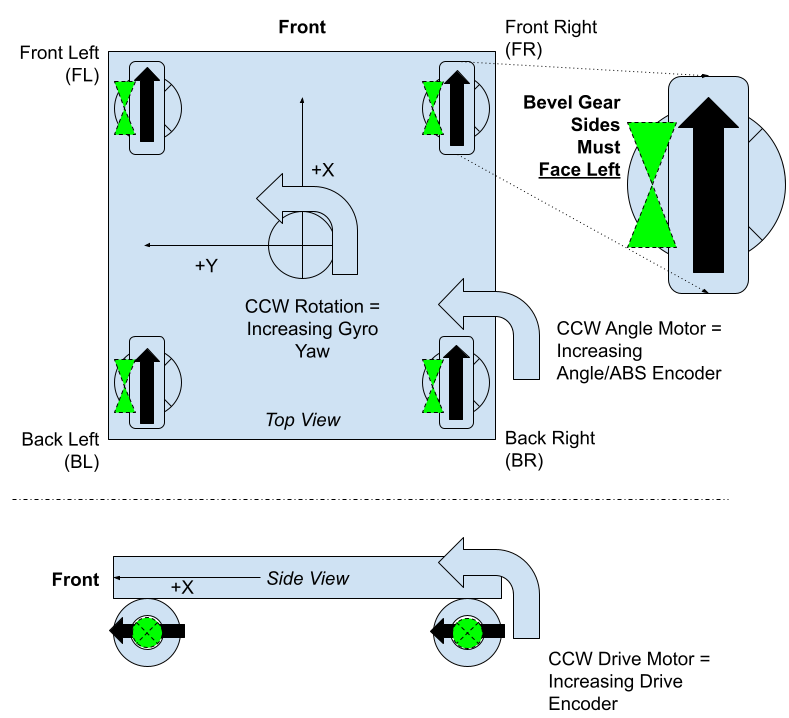
## Swerve drive diagram
{% hint style="danger" %}
Older gyroscopes like the Pigeon 1 and NavX 1 drift the longer they're powered on. Consider rebooting or zeroing your gyroscope at the start of your program.
{% endhint %}
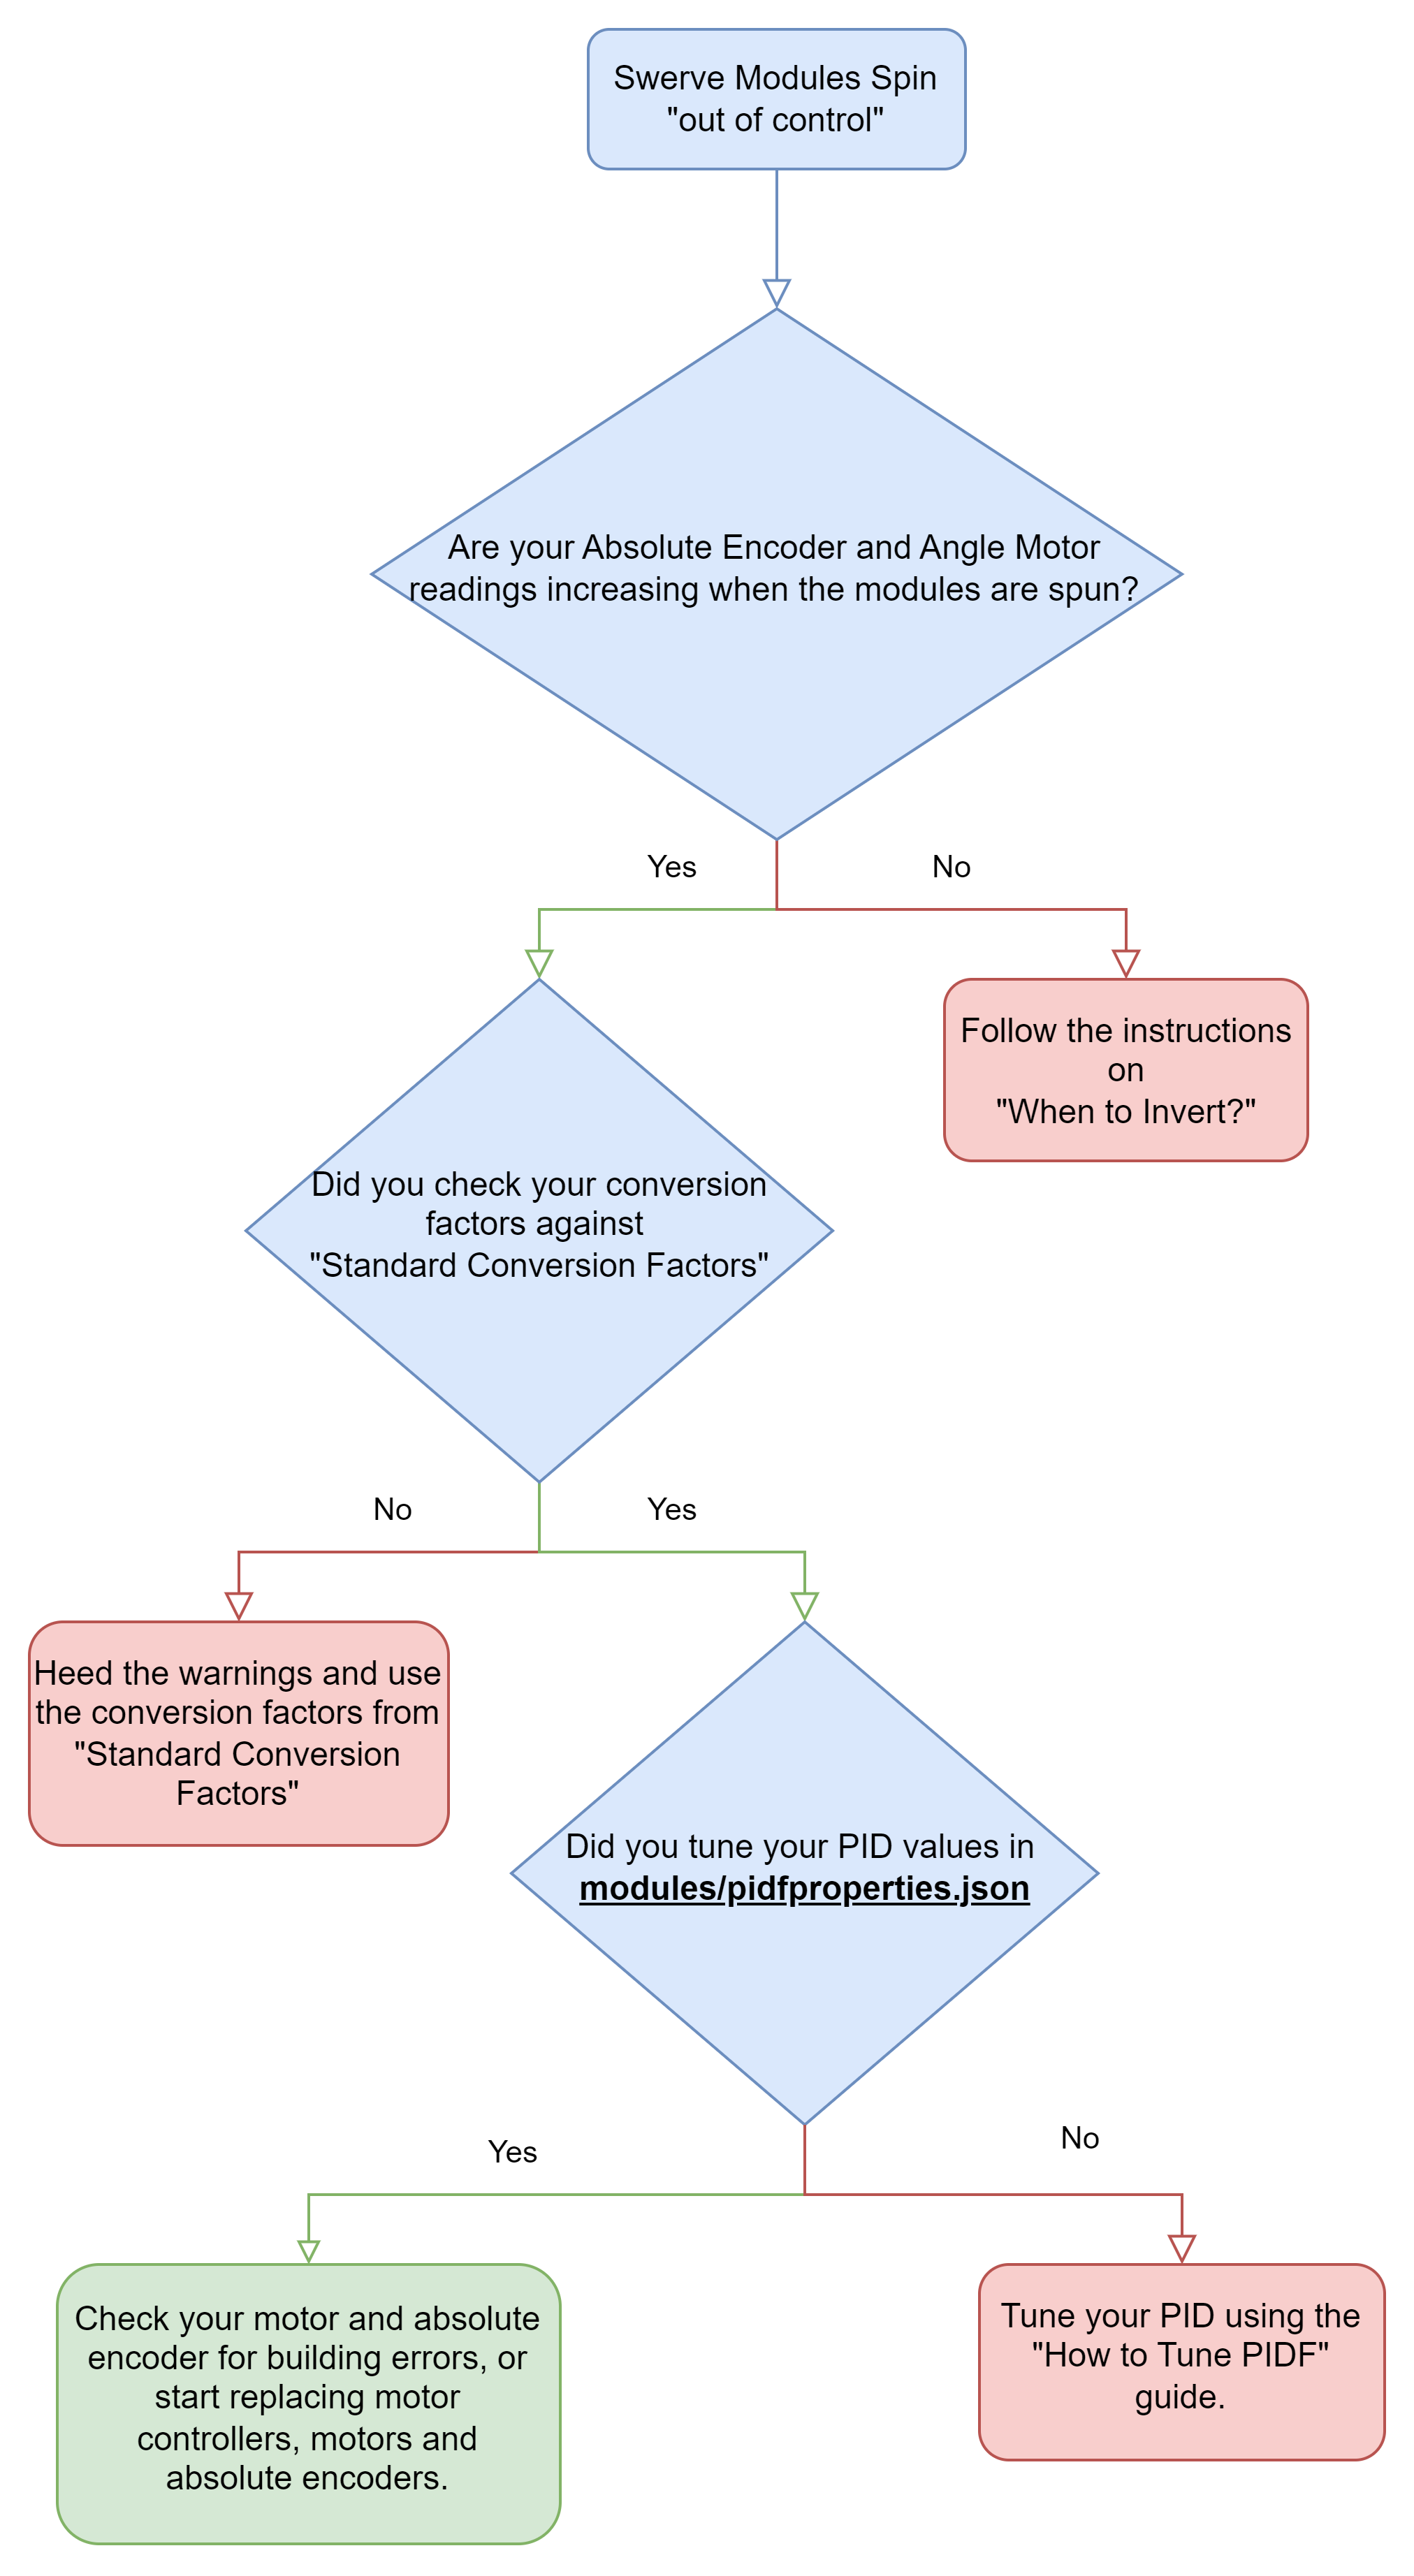
## Swerve modules spinning "out of control"
## Swerve module does not spin correctly
1. Are the CAN IDs, motor types, and absolute encoder types correct? See the [device reference](/reference/hardware.md) for supported type strings.
2. Are the module `location`s correct?
3. Do you use an absolute magnetic encoder?
1. Did you loctite the magnet in?
2. Do you have a good (usually green LED) reading on the magnet?
4. Did you set `absoluteEncoderOffset` while the wheels had the bevel facing left and the wheel pointed straight front-to-back?
5. Did you check [how to determine inversion](/how-to-guides/determine-inversion.md) for inversion states?
6. Did you [tune your PID](/how-to-guides/tune-pidf-gains.md)?
If none of the above resolves it, move on to [The 8 steps](/how-to-guides/the-8-steps.md).
## Swerve drive "spins out of control"
See [how to determine inversion](/how-to-guides/determine-inversion.md) and [the 8 steps](/how-to-guides/the-8-steps.md).
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://yagsl.yassrobotics.com/how-to-guides/troubleshooting-flowchart.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.